Normally, working out precisely where a moving device is — not just roughly, but its exact position, its speed, and how far off its internal clock is — takes a lot of infrastructure. Classic satellite navigation (GPS-style) needs signals from several satellites at once. Cellular network positioning usually needs a connection to several towers at the same time, which isn’t always available. Researchers at Chalmers University of Technology (working with Volvo, Universitat Autònoma de Barcelona, and others) set out to see how far you could strip that down.
The core idea: use what’s already there, together
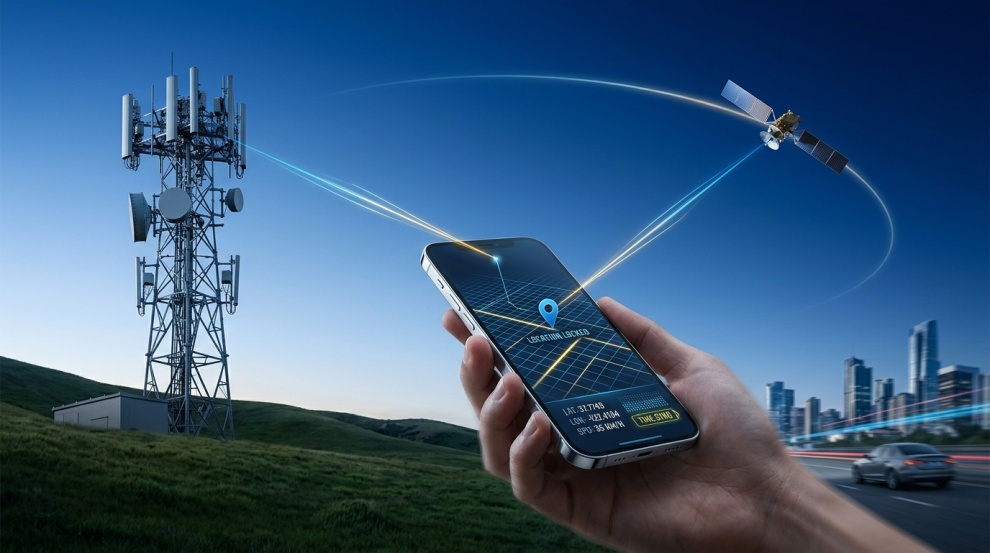
Their answer is a “minimal setup”: just one ordinary ground-based cell tower plus one low-orbit (LEO) satellite, working together at the same time. The phone (or car, or any device) listens to both signals at once, and by carefully comparing timing, angle, and frequency information from each, the system can work out the device’s position, its speed, and how far its clock has drifted — all without needing the four-or-more base stations that conventional cellular positioning usually requires.
Why this is hard, and how they solved it
Combining a nearby, stationary tower with a satellite racing overhead at roughly 7,800 metres per second is trickier than it sounds. The satellite’s motion (and the Earth’s own rotation) creates a strong Doppler effect — a frequency shift caused by relative movement, the same phenomenon that makes an ambulance siren change pitch as it passes you. On top of that, the device itself is moving, and its own internal clock is not perfectly synced with the network’s.
To handle this, the researchers built one full, highly detailed mathematical model of the situation that accounts for all of this — device movement, clock drift, and Doppler shift, including how it plays out differently across time and across different radio frequencies. Because that full model is complex to compute, they then built four simplified versions of it, ranked from lightest to heaviest:
- The simplest version ignores Doppler almost entirely — fast to compute, but only accurate when the device is barely moving.
- The most complete version accounts for Doppler in full detail, including subtle interference effects between neighboring frequency channels — much more demanding to compute, but noticeably more accurate, especially at higher speeds or with a larger clock error.
Engineers designing hardware can then pick whichever version fits their situation: a lighter model where resources are limited, or the full model where top accuracy matters more than computing cost.
How well it actually performed (in simulation)
In their simulated tests, the most complete model came close to the theoretical best-possible accuracy even under a fairly large clock error, reaching centimeter-level position accuracy in that scenario. The two more advanced models were also able to estimate the device’s speed to better than 1 meter per second and its clock-frequency error to a very fine fraction of a part-per-million — all without needing more than the one tower and one satellite. As expected, the very simplest model struggled once the device was actually moving at realistic speeds, which is exactly the trade-off the researchers set out to map.
Why this could matter down the road
Because low-orbit satellites are meant to help 6G networks cover places ground towers can’t reach well — forests, mountains, remote roads — a method like this could let a device get an accurate position fix using just whatever single tower and single satellite it can see, rather than needing a strong signal from several base stations. And because the approach explicitly plans for lighter, cheaper computation options, it’s reasonable to expect that could translate into less processing load — and so less battery drain — on a real device, even though the paper itself doesn’t measure that directly. The same accuracy-under-movement focus is also relevant to fast-moving vehicles, where the paper specifically points to autonomous driving and driver-assistance systems as an application that needs reliable location and timing information even as conditions change quickly.
Where things stand
This is a research paper validated through computer simulation, not a deployed or field-tested system. The team compared their four models against theoretical accuracy limits across a range of simulated conditions (different speeds, clock errors, and satellite positions) to work out which model suits which situation — useful groundwork for how future 6G networks might approach positioning, but not yet something running in a real phone or car.
Original abstract: this paper investigates the localization, synchronization, and speed estimation of a mobile user equipment (UE) leveraging integrated terrestrial and non-terrestrial networks (NTNs), in particular low Earth orbit (LEO) satellites. We focus on a minimal setup in which the UE received signal from only one base station (BS) and one LEO satellite. We derive a generic signal model accounting for mobility, clock and frequency offsets, based on which a hierarchy of simplified models are proposed and organized by computational complexity. Estimation algorithms are developed for each model to facilitate efficient and accurate parameter recovery. Rigorous simulations validate the effectiveness of the proposed models, demonstrating their suitability across diverse scenarios. The findings highlight how the trade-off between complexity and performance can be optimized for varying deployment environments and application requirements, offering valuable insights for 6G positioning and synchronization systems under user mobility.
Transparency Note: This article was prepared with the assistance of artificial intelligence technologies. Every piece is thoroughly reviewed and verified by our editorial team, who retain full responsibility for the final content.
Picture: Gemini AI